Process images with a point-spread function
Use spacr.point_spread from Python to convolve an image with a
point-spread function (PSF), or to deconvolve it with Richardson–Lucy.
Prepare a two-dimensional image or three-dimensional volume and a measured
PSF sampled at the same pixel or voxel spacing. Supply intensity images;
keep object-label masks separate.
Use the desktop controls
In Make Masks, open Image enhancement and select Convolve (blur) or Deconvolve (Richardson–Lucy) under Point spread function. Choose your Objective, or use Infer from images… to read the current image’s optical metadata. With no image open, the button asks you to choose a TIFF. The summary shows pixel spacing, Gaussian width and where those values came from.
Open PSF optics and kernel to inspect the remaining controls. Camera sets the camera pixel pitch; Fluorophore sets the emission wavelength. Magnification, numerical aperture, immersion refractive index, wavelength, pixel spacing and Gaussian widths remain editable. Labels identify metadata, objective-table values, calculations, defaults and values you entered. Review these after using Infer from images…, which repopulates the optics and recalculates Gaussian widths.
Without image-specific information, the starting approximation uses a 20×/0.75 air objective, a 6.5 µm camera pixel and 520 nm emission. It gives 0.325 µm image pixels and approximately 0.354 µm Gaussian FWHM. Pixel spacing is camera pixel pitch divided by magnification; the lateral Gaussian FWHM is approximated by 0.51 × emission wavelength / numerical aperture. These defaults permit a calculation; they are not measured calibration or proof of your microscope’s resolution. Check them against the acquisition.
In the same fold, choose Measured kernel (TIFF/NPY) and load your calibrated two-dimensional PSF, or keep Gaussian approximation. For a measured kernel, enter its pixel spacing too; it must match the image. Neither mode silently resamples a mismatched kernel.
Wait for the kernel to load, then use Compare to inspect its effect. Set Deconvolution iterations when using Richardson–Lucy and choose Apply to use the result for detection. Start with a modest iteration count and inspect noise as well as object boundaries. Reload rereads a kernel file after you change it. Off disables PSF processing.
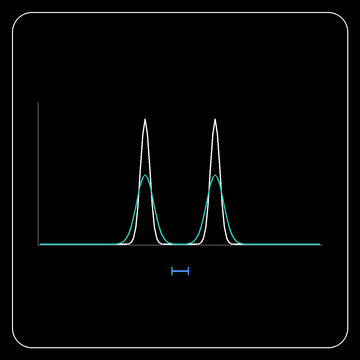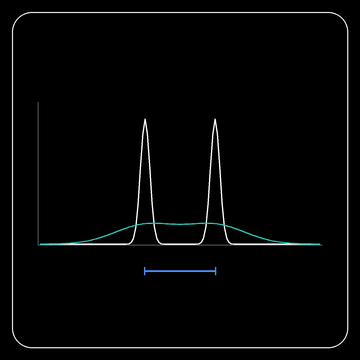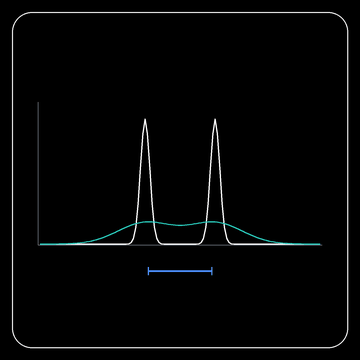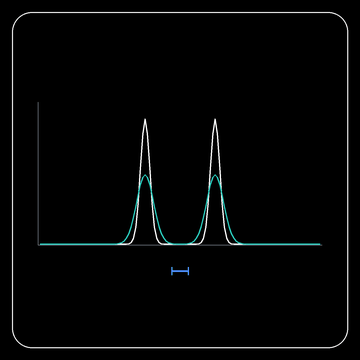
White shows a fixed input profile; teal shows the convolved result. The blue bar indicates the Gaussian kernel’s full width at half maximum. Increasing that width spreads the signal and reduces peak intensity while preserving the integrated intensity. This illustrates convolution with a Gaussian approximation. For your microscope, enter measured calibration values and inspect the resulting image with Compare.
For a batch in Mask, including a run with the Timelapse switch on,
open the Point Spread Function settings category. Set psf_operation to
convolve or deconvolve and psf_image_sampling_um to your calibrated
[Y, X] pixel spacing.
For psf_source="measured", select psf_path and matching
psf_kernel_sampling_um. For psf_source="gaussian", supply
psf_fwhm_um instead. psf_iterations controls deconvolution work.
For Gaussian processing in Mask, Timelapse and Mask Live preview, unset
image sampling and FWHM can be inferred from the first source image’s
metadata and psf_objective. auto uses available image metadata,
then the common defaults described above; an objective-table choice supplies
that objective’s values. Explicit sampling and FWHM take precedence. Review
the reported values and their sources before accepting a run. Measured
kernels and Measure still require explicit calibration.
Run preprocessing to rebuild the segmentation inputs after changing these
settings. One kernel is applied independently to each selected segmentation
channel, after illumination correction and before normalization. Check that
its calibration is appropriate for all selected channels. The batch operates
on two-dimensional projected fields; time-series frames are processed
independently. Original image intensities remain unchanged for measurement.
Keep psf/segmentation_application.json with the results: it identifies the
kernel and processing settings. Reusing existing preprocessing requires an
exact completed match. See spacr.psf_pipeline.prepare_psf().
Inspect Mask Live preview
After setting up the PSF, open Live in Mask and choose a representative field. The preview applies the selected kernel before background thresholding and model normalization. Inspect the mask boundaries and processing details, then try another field before running the batch. Raw-intensity object filters continue to use the original intensities.
Live preview normalizes the selected field and does not apply the full pipeline’s illumination correction. A full Mask run may normalize across a batch, so review its saved masks as well as the preview. Changing settings requires a new detection; processing details describe the accepted result.
Choose the intensities used by Measure
In Measure, open Point Spread Function and set
psf_measurement_source. Keep original for the standard measurement
intensities, including Measure’s normal rescaling and preprocessing, without
additional PSF processing. Choose processed to measure intensities after
convolution or deconvolution, then configure psf_operation, the kernel
source and its calibration.
For a two-dimensional field, enter image sampling and Gaussian widths in
[Y, X] order. For a volume, use [Z, Y, X] and a matching
three-dimensional kernel. Volume sampling must agree with Measure’s voxel
calibration or anisotropy settings. A measured kernel must have the same
sampling as the image. Use a kernel appropriate for every selected intensity
channel.
Run Measure and inspect the resulting object-feature tables in
measurements.db. PSF processing changes the intensity stream used for
quantitative features; source files and exported crops retain their usual
behavior. The intensity_rescale table records the selected source and PSF
processing details. Keep the database with the settings and kernel file.
To compare different kernels or original and processed measurements, use
separate projects or output databases. An existing database cannot mix
measurements made with different PSF configurations. Restore the recorded
configuration when resuming a run. See
spacr.psf_measurement.prepare_measurement_psf() for the Python settings
contract.
Load the image and PSF
The example below reads a single-channel image and a measured PSF from TIFF files. Replace the example spacing of 0.11 µm with your calibrated Y and X pixel spacing. A three-dimensional input uses Z, Y and X spacing in that order. The PSF must have odd spatial dimensions, a central origin and nonnegative signal after background removal.
import json
from pathlib import Path
import tifffile
from spacr.point_spread import load_psf, apply_psf

spacing = (0.11, 0.11)
image = tifffile.imread("cell_channel.tif")
kernel = load_psf("measured_psf.tif", sampling_um=spacing)
Choose the operation and save the result
Set operation="deconvolve" to perform Richardson–Lucy deconvolution.
Start with a modest iteration count and compare the result with the input;
more iterations can amplify noise. operation="convolve" instead blurs
the image with the PSF. It does not use the iteration count.
result = apply_psf(
    image,
    kernel,
    operation="deconvolve",
    image_sampling_um=spacing,
    iterations=10,
)
tifffile.imwrite("cell_channel_deconvolved.tif", result.image)
Path("cell_channel_deconvolved.json").write_text(
    json.dumps(result.provenance, indent=2), encoding="utf-8"
)
The output preserves the image shape and uses float32 values in the original intensity units. Inspect its range before converting it to an integer image. Keep the JSON record with the result; it contains the kernel identity, sampling and processing settings.
For multichannel images, set channel_axis explicitly: -1 selects a
final channel dimension, while 0 selects a first channel dimension.
Each intensity channel is processed independently. Image and PSF sampling
must match; the function rejects mismatched spacing.
Use a calculated approximation
If your workflow calls for a Gaussian approximation, construct it with
spacr.point_spread.gaussian_psf(). Supply the full width at half maximum
in micrometres and the image spacing. These are example values to replace
with the values appropriate to your analysis:
from spacr.point_spread import gaussian_psf

kernel = gaussian_psf(
    fwhm_um=(0.30, 0.30), sampling_um=spacing, ndim=2
)
Pass this kernel to apply_psf as above. A Gaussian kernel is an
approximation; retain that distinction when comparing it with a measured
PSF. See spacr.point_spread.apply_psf() for cancellation, progress
callbacks and the complete parameter reference.